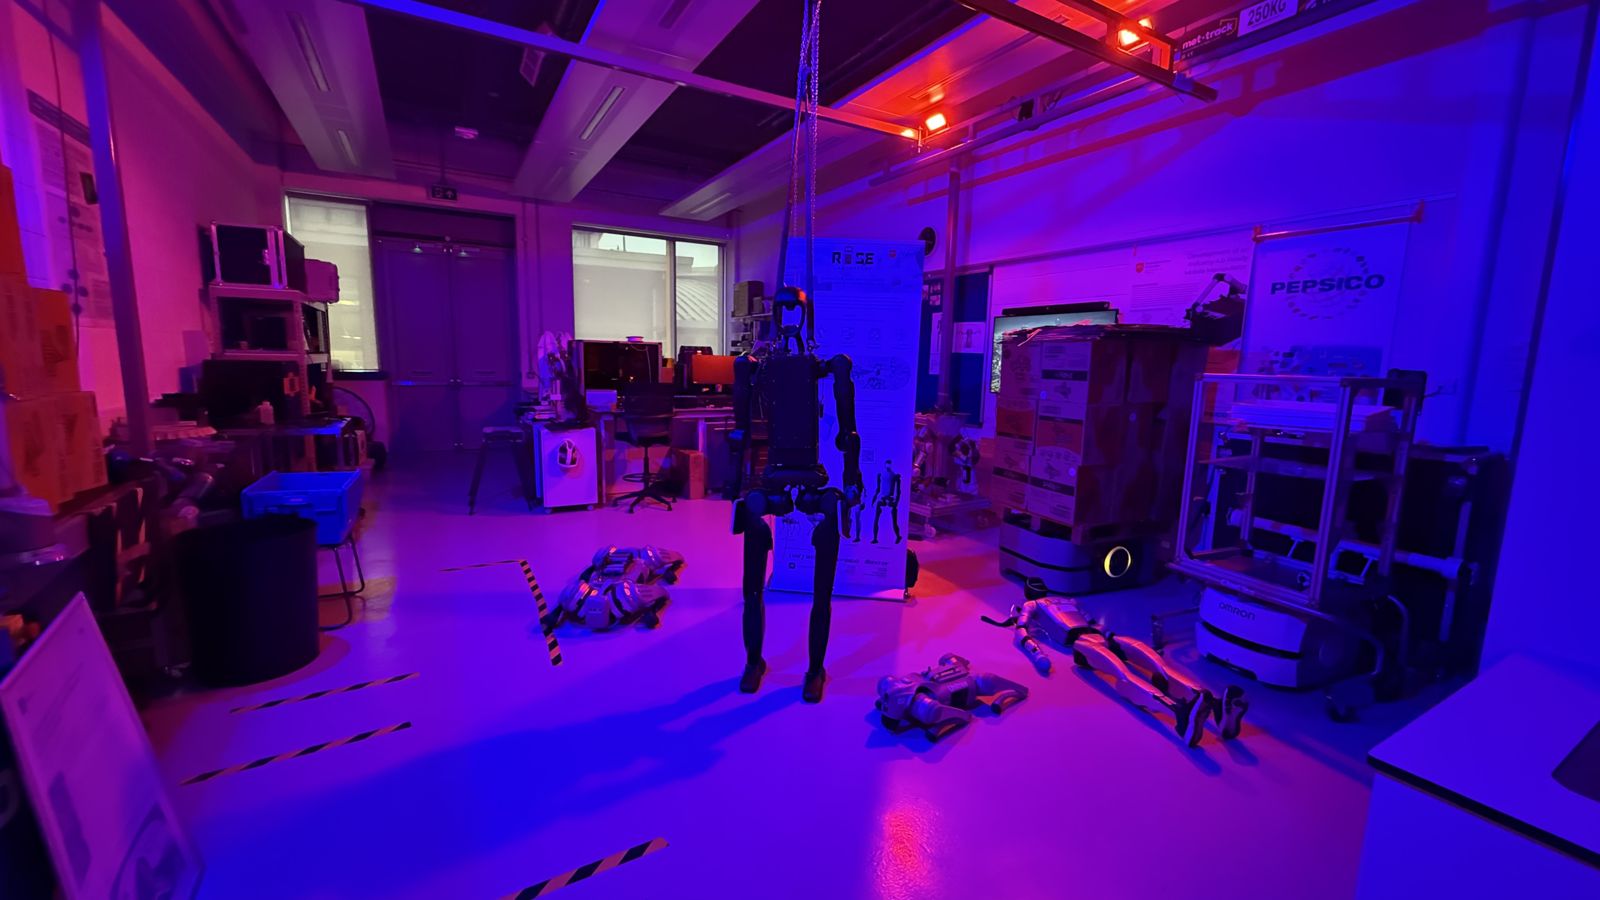
Humanoid robotics
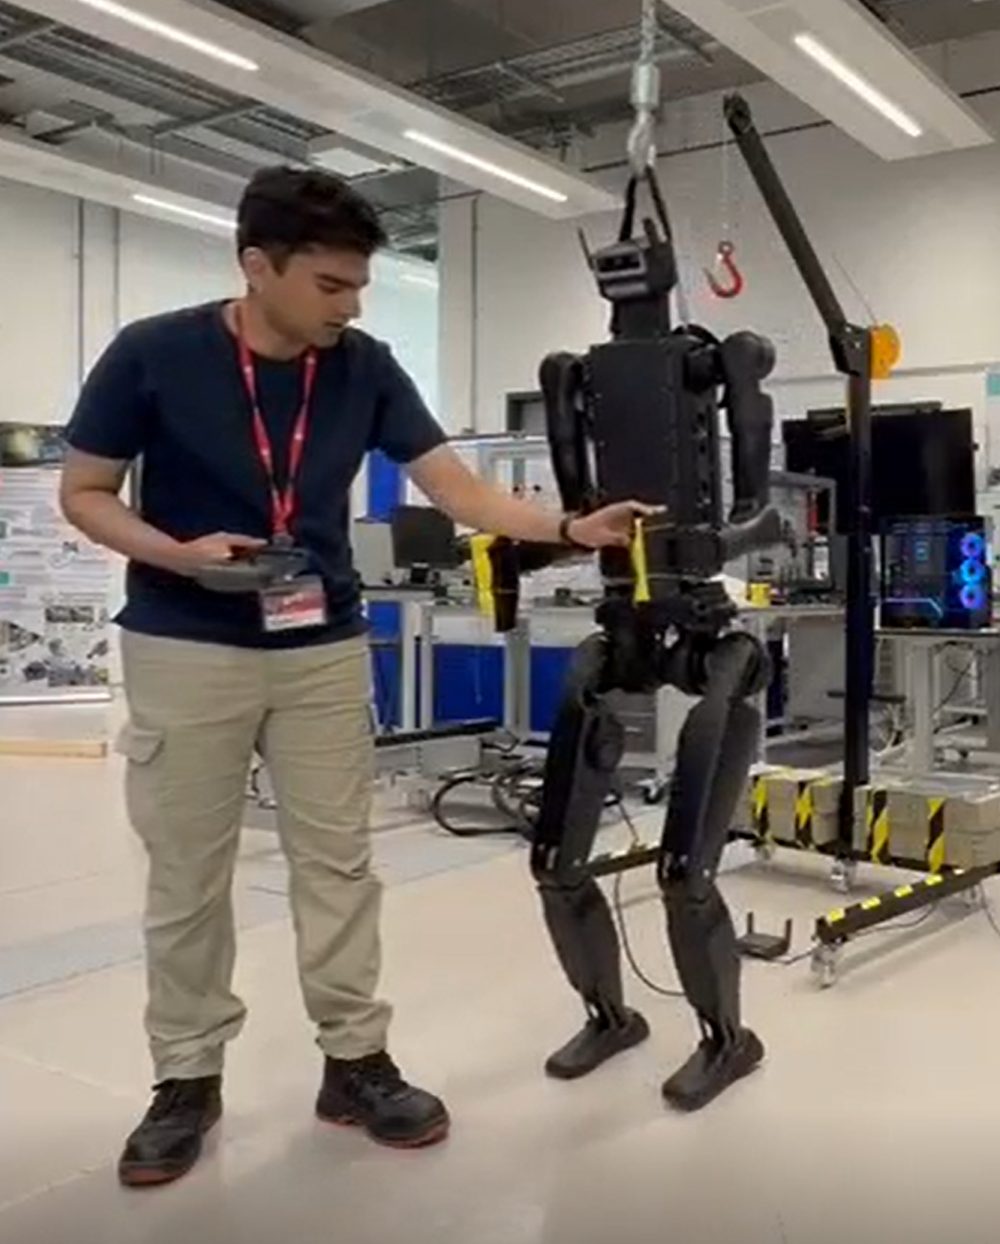
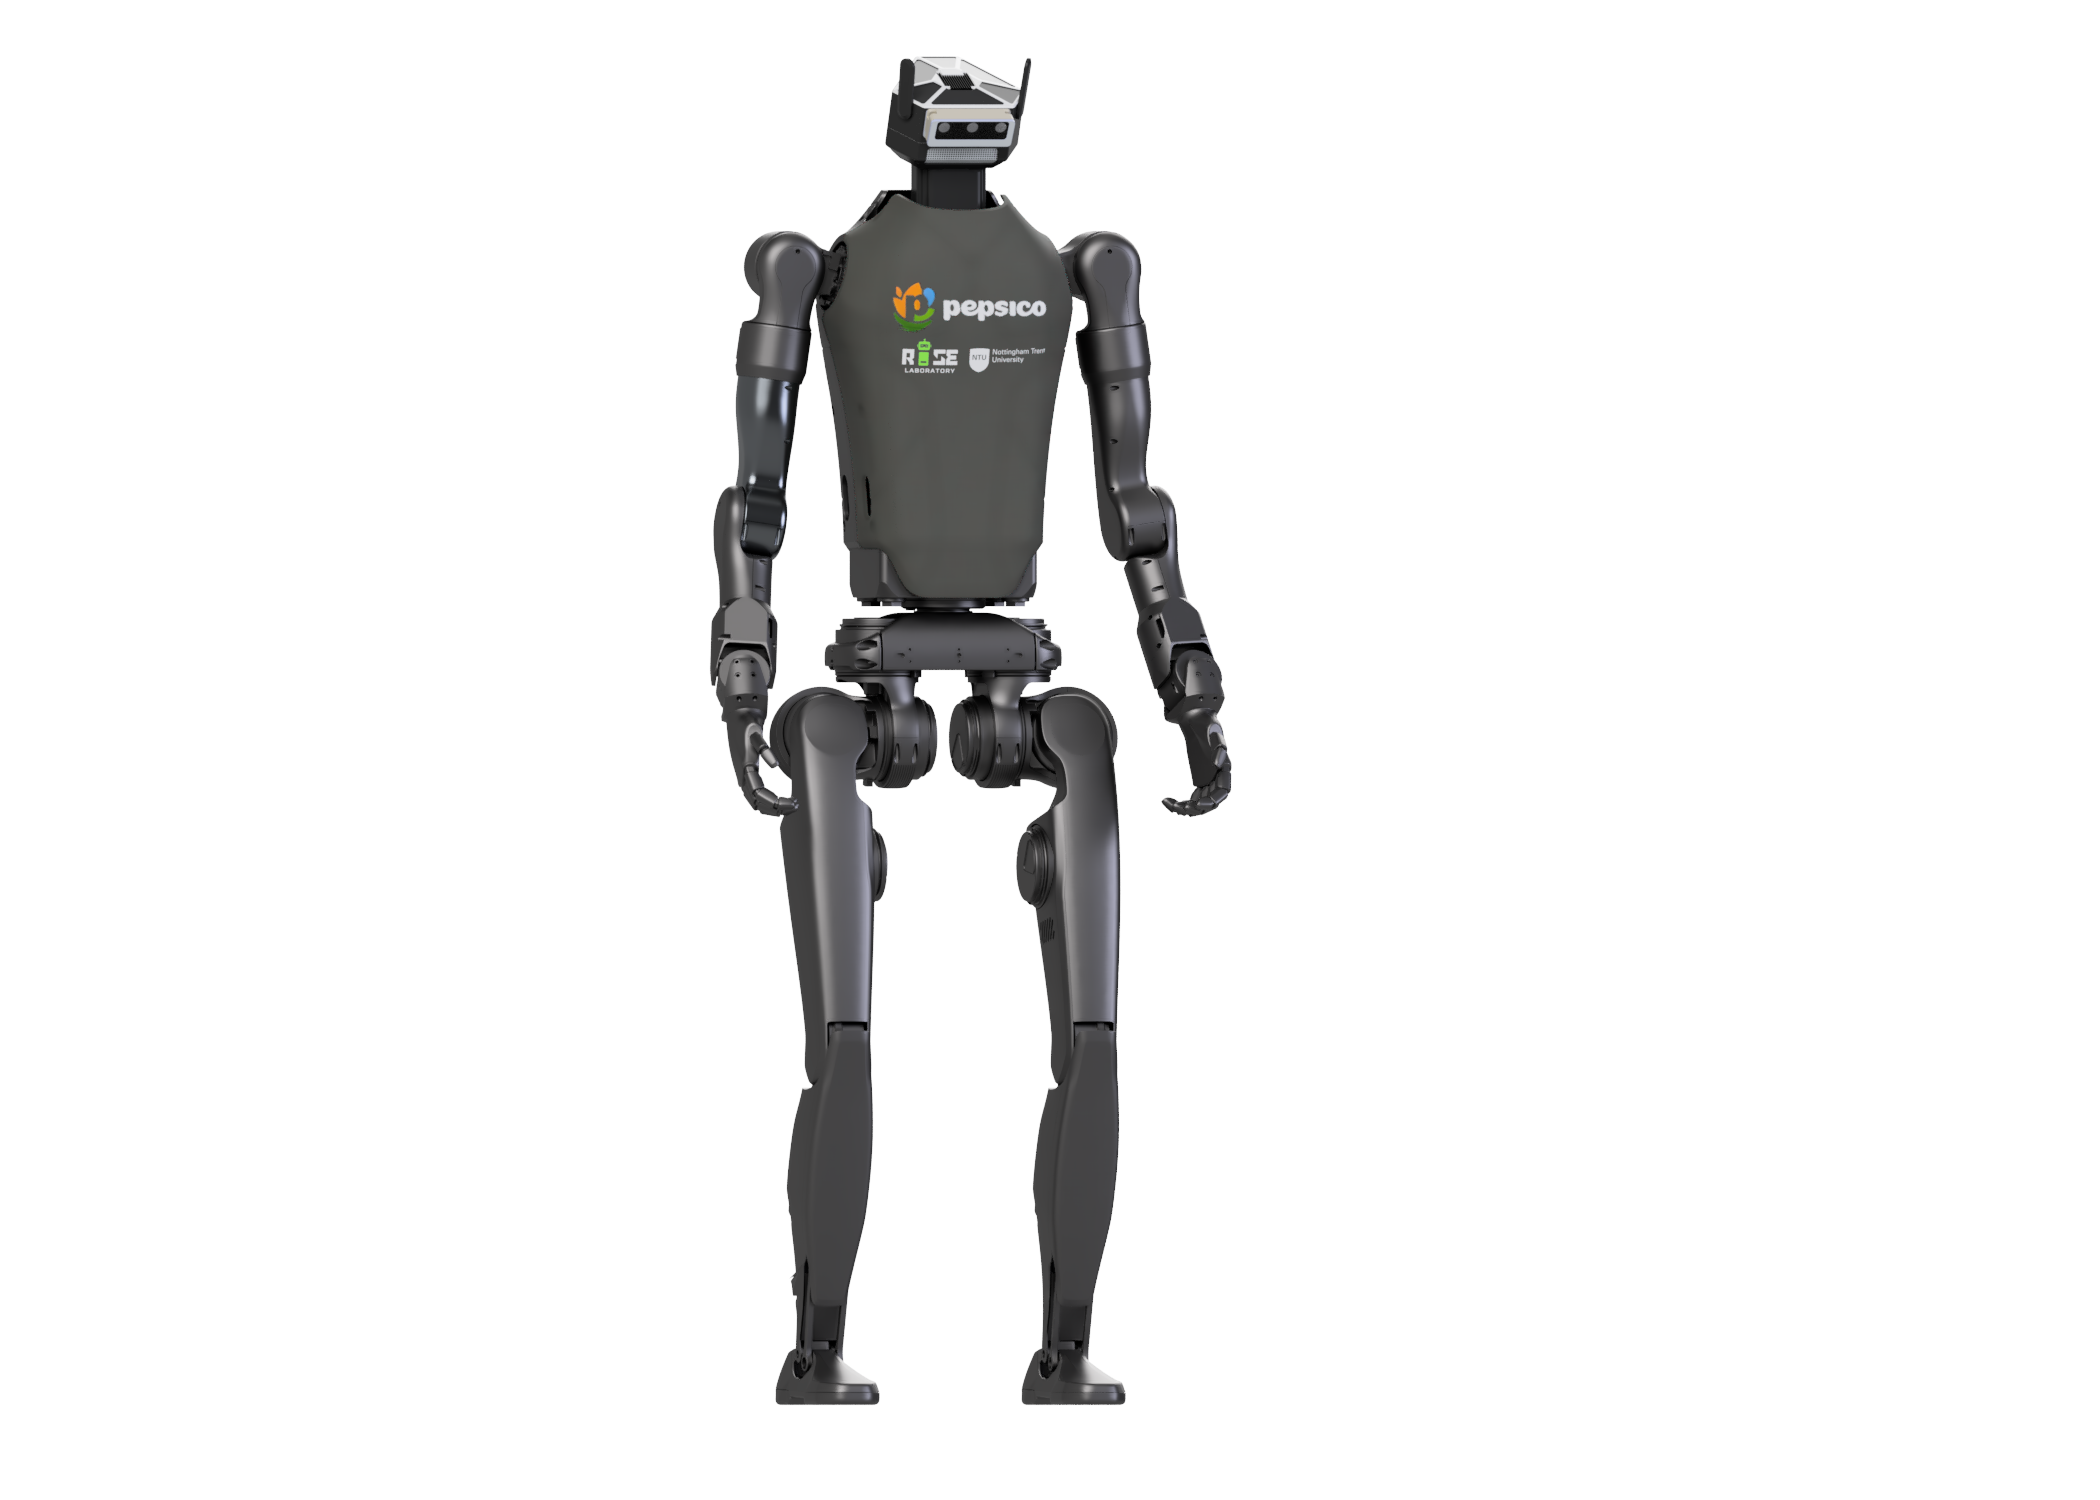
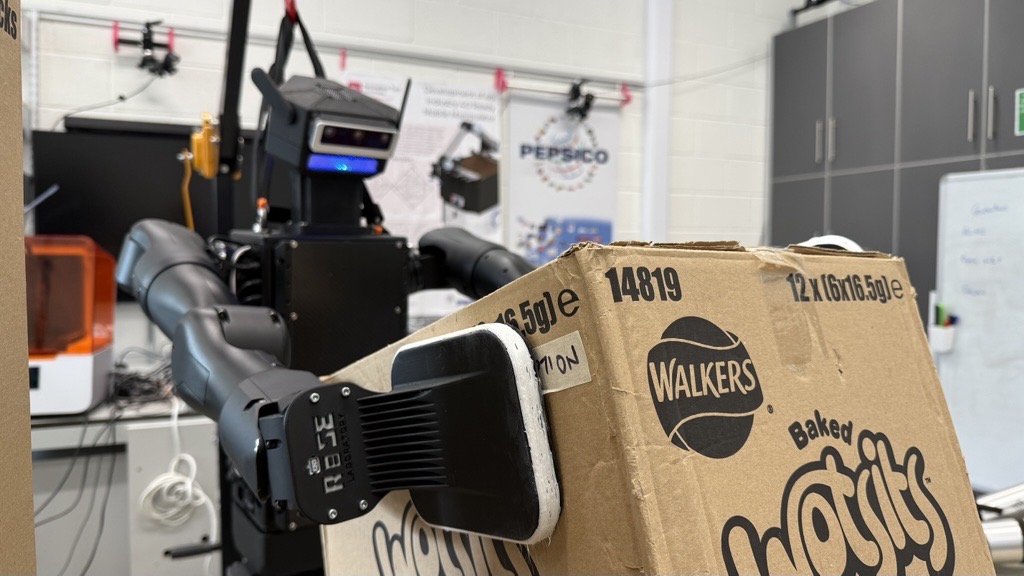
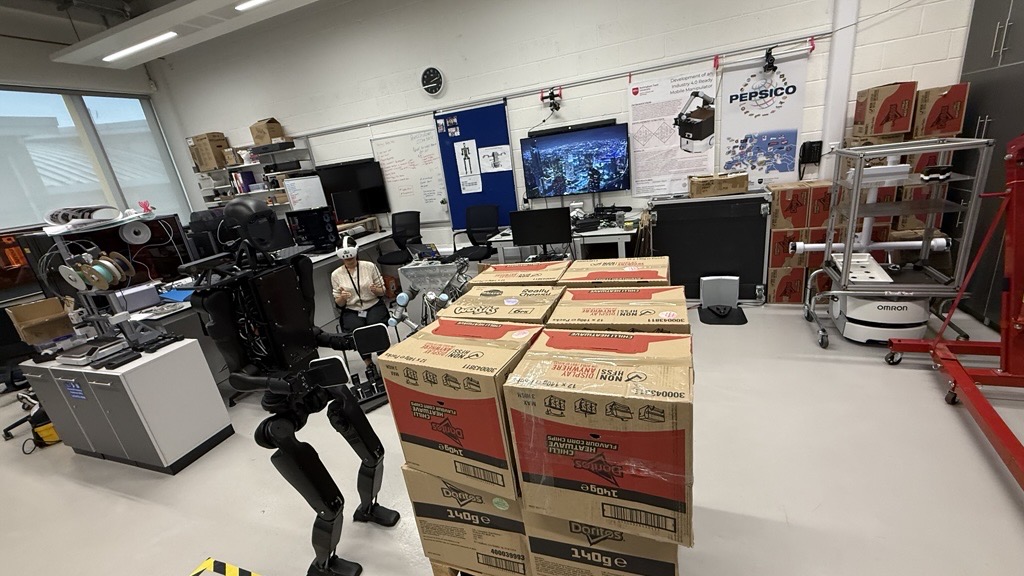
For two years, Rakshith programmed industrial use cases on Unitree H1-2 and G1 humanoid robots for a PepsiCo programme. Each use case put a real industrial task on a legged robot.
What
The programme put defined industrial tasks, such as case handling and palletising, on Unitree H1-2 and G1 humanoid robots. Learned neural policies controlled the locomotion. The gait was not scripted.
How
Rakshith trained the policies for legged control in simulation, then transferred them to the real robots. System identification on the actuators showed where the real torque response and compliance differ from the simulation model.
Rakshith also added instrumentation to record the failure modes that occur only on hardware. A controller that works in simulation can fail on a real actuator. For this reason, the actuator is identified before the controller is trusted.
Results
The programme delivered use cases on both robots. It also produced a transfer method, "identify the system before trusting it", which Rakshith has used on every project since.
Photographs
Select a photograph to enlarge it