Rakshith Bangalore
Rakshith Bangalore Kumaraswamy · Robotics solutions architect · United Kingdom and Singapore
A hands-on robotics engineer across hardware and software. Rakshith was involved in starting a robotics programme at Nottingham Trent University and learnt most of the craft on real robot hardware.
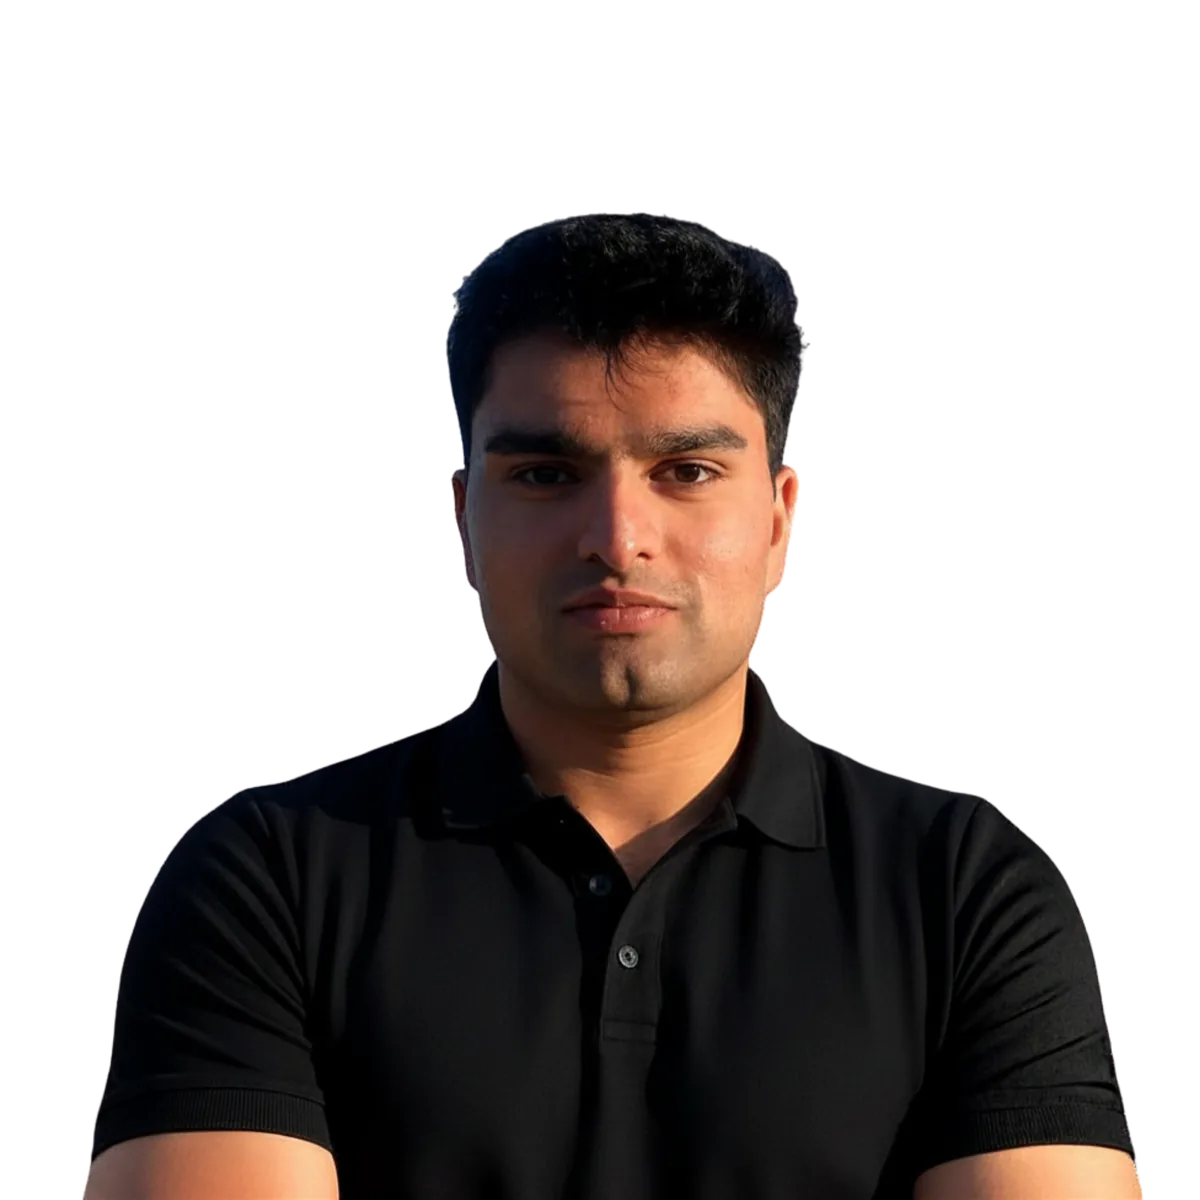
Profile
Rakshith Bangalore (full name Rakshith Bangalore Kumaraswamy) is a robotics solutions architect based in the United Kingdom and Singapore. The work covers humanoid robot R&D, robot simulation, mobile manipulation, manufacturing automation and hardware products. Rakshith holds an MEng from Nottingham Trent University and was involved in starting a robotics programme there.
For two years, Rakshith programmed industrial use cases on Unitree H1-2 and G1 humanoid robots for a PepsiCo programme. The work included neural policies for legged control, sim-to-real transfer and actuator identification.
Day to day, the work meant running demos, teleoperating the robots, building reinforcement learning pipelines, and reading and testing different methods to make humanoid robots work in industrial settings. Most of what Rakshith knows was learnt this way, hands-on with real hardware.
Rakshith also delivers products end to end: an AI-enabled full-stack software platform, and a portable hardware product from prototype to its first production run. Rakshith is the author of WardZero, an open simulation platform for hospital robots, and the host of the Unfiltered Robotics podcast.
Rakshith now works with startups and businesses that are starting a robotics programme. Rakshith can get hands-on from the first week: knowing what to prioritise, what to build first, and which demos help to win clients. See the services.
“Identify the system before you trust it.”
A controller can work in simulation and fail on a real actuator. An AI feature can work in a demo and fail on the fifth job of the day. In both cases, the parts around the model cause the failure. Rakshith applies the same method to robots and to software.
Strengths
What Rakshith brings to a robotics teamHands-on from day one
Involved in starting a robotics programme at Nottingham Trent University. Runs demos, teleoperates robots and builds reinforcement learning pipelines on real hardware.
Hardware and software
Mechanical design, integration, BOM and DFM on one side; ROS 2, simulation, reinforcement learning and control on the other.
Current robotics stack
Humanoid robots (Unitree H1-2 and G1), sim-to-real transfer, Isaac Sim and MuJoCo: the tools that physical AI teams use now.
Industry partners
Projects scoped with PepsiCo, Walkers, an NHS Trust and the EU Clean Sky 2 programme, around real workflows.
Career history
Most recent firstWardZero
- Created an open platform to develop and test hospital robots in simulation, with Isaac Sim, MuJoCo and ROS 2.
- Built a simulated hospital with a surgical wing, a safety layer with seven modes, teleoperation and navigation.
- Trained the first controller stage: survival increased from 0.05 to 0.97 in 39 million steps.
AI-enabled full-stack software
- Manages the delivery of an AI post-production platform, with a web application and a Premiere Pro integration, through its live pilot.
- Links two software engineers and senior management. Plans sprints in JIRA, records decisions in Confluence and maps workflows in Miro.
- Onboarded two podcast studios. Post-production time per episode decreased from four days to four hours.
Portable podcasting solution
- Manages a portable recording studio from working prototype to its first production run.
- Controls production timelines with manufacturers in China, the BOM and DFM files, and the budget.
- Runs the pre-sale, the Kickstarter campaign, the lead funnel and the entry into the US market.
Unfiltered Robotics
- Hosts a podcast about legged robots, hobby builds and hardware development.
Robotics programme, Nottingham Trent University
- Involved in starting a robotics programme at Nottingham Trent University.
- Ran demos and teleoperation sessions, built reinforcement learning pipelines, and read and tested different methods to make humanoid robots work in industrial settings.
Humanoid robotics
- Programmed industrial use cases, such as case handling and palletising, on Unitree H1-2 and G1 humanoid robots.
- Trained neural policies for legged control in simulation and transferred them to the real robots.
- Identified the actuators and recorded the failure modes that occur only on real hardware.
Industrial automation
- Designed autonomous mobile robots for industrial palletising in a production area in operation.
- Developed a reverse-engineering pipeline that changes physical parts into CAD for manufacture, with sub-millimetre accuracy.
MEng, Nottingham Trent University
- Capstone: an Industry 4.0 mobile manipulator, scoped with Walkers. The project won the capstone award.
- Project manager of an eight-person team that developed a laparoscopic surgery trainer with an NHS Trust.
- Two years on an aircraft cabin laboratory for EU Clean Sky 2 research, then a summer research scholarship on its audio equaliser.
- Founded the robotics club and the drone society.
- CERT student mentor, then lead student mentor; student ambassador for open days and campus tours.
- Joined a research flight to the Netherlands on turboprop comfort.
- Learning designer for the university's online learning assets; published engineering content on a YouTube channel.
Capabilities
Robotics · Software · DeliveryRobotics
- Legged control and neural policies
- Sim-to-real transfer and actuator identification
- Mobile manipulation and tool changing
- Force feedback and compliant mechanisms
- Autonomous navigation
Software and simulation
- ROS 2, Nav2 and slam_toolbox
- Isaac Sim, MuJoCo and MuJoCo MJX
- Reinforcement learning (PPO) and ONNX
- MATLAB, Python and CUDA
- Fusion 360 and Ansys
Product and delivery
- Software project management
- Hardware product management
- BOM, DFM and supplier management
- Pilot onboarding and market entry
- JIRA, Confluence and Miro