WardZero: a simulated hospital for robots
WardZero is an open platform, created by Rakshith, to develop and test robot solutions for hospitals. It provides a full simulated hospital, two simulators, a safety layer and navigation. Robots train in WardZero before they work near patients.
Film
The hospital and surgical wing in Isaac Sim 6.0, path traced. The camera moves on a scripted path; it is not a robot view.
Results in simulation
Wall cells within 0.10 m of the Isaac ground truth
Of the floor that the robot can reach
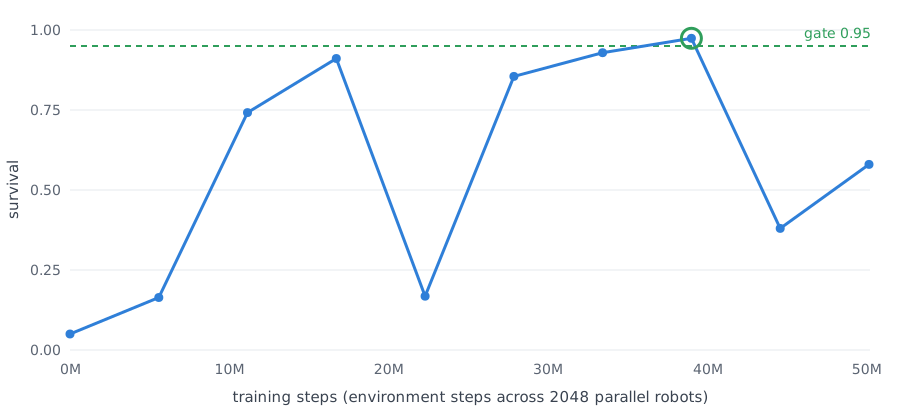
Stage A1, in 39 million steps
On one RTX 3070 GPU
What
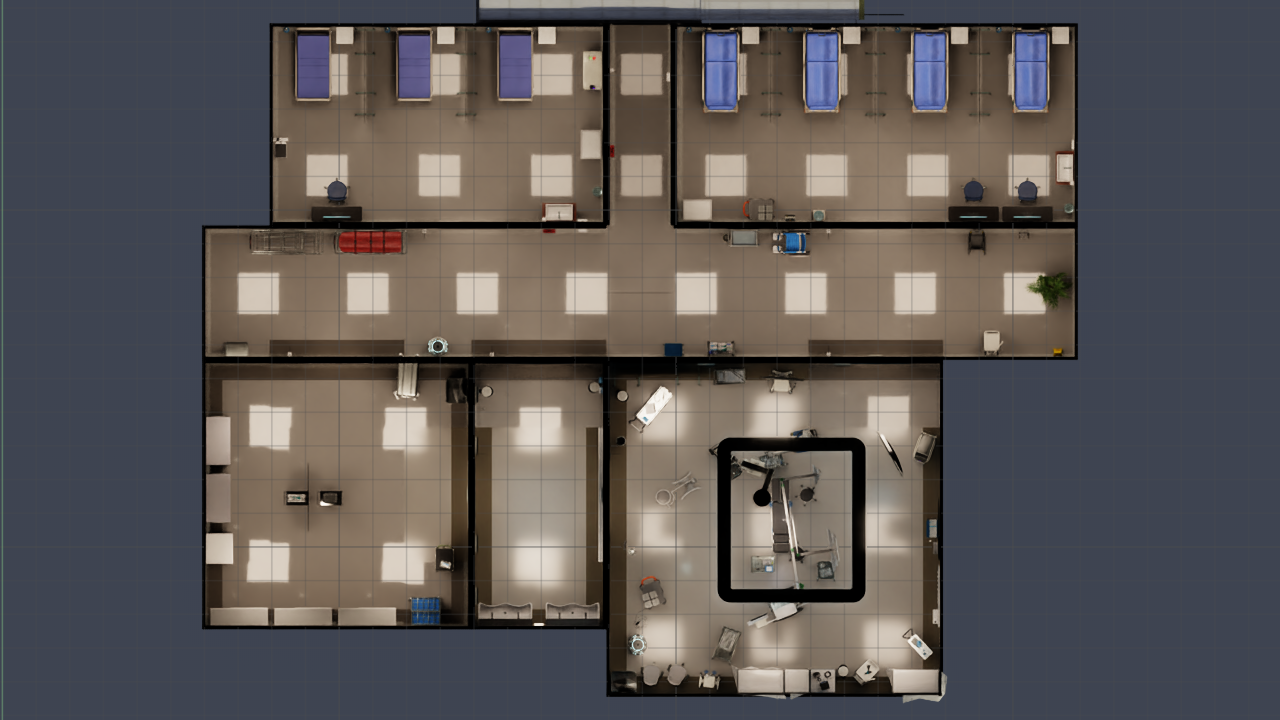
WardZero is a full simulated hospital for robot development. The surgical wing has corridors, pre-operative bays, a recovery ward, a sterile store, a scrub room and an operating theatre. Users can bring their own robot, controller or task. The platform supports mapping, navigation, controller training, teleoperation, safety functions and robot tasks, and it records synchronised sensor data with exact ground truth.
How
All parts use the low-level interface of the real robot. The controller sends motor targets on /lowcmd at 500 Hz and reads joint states on /lowstate. As a result, the same software runs in MuJoCo, in Isaac Sim and on the real robot.
The component repositories with the prefix hospital-sim- contain no robot-specific code. A different robot supplies its own model, simulator bindings and controller, so the platform is robot agnostic.
Results
The hospital, both simulators, the safety layer, teleoperation, mapping and navigation are complete. The controller has completed training stage A1 (stand). All tests used simulation only; no test on a real robot and no sim-to-real test is complete yet.
System architecture
Select the diagram to enlarge it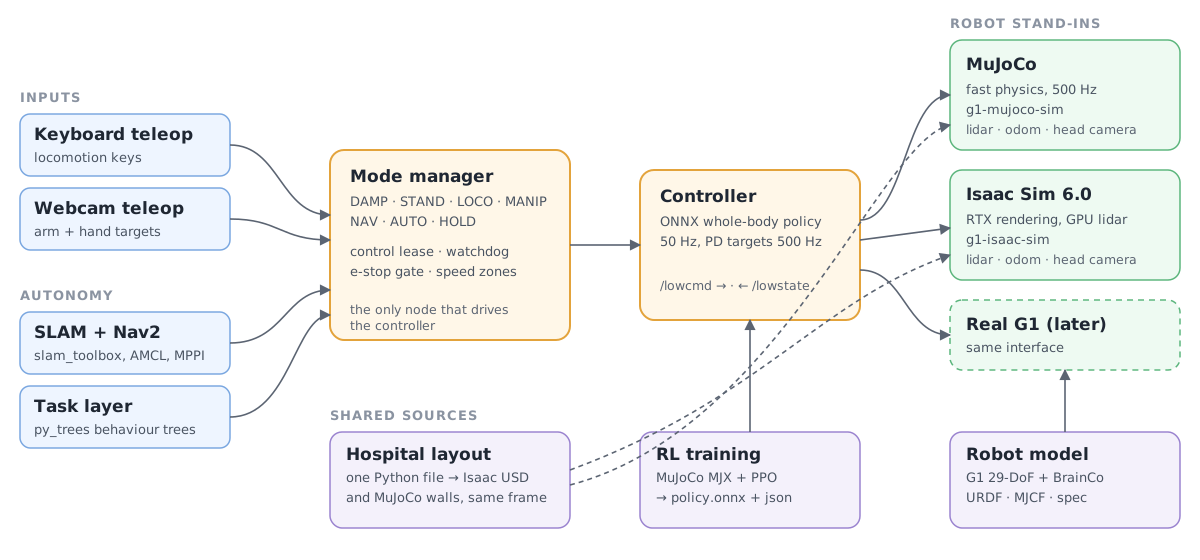
One interface
The controller sends /lowcmd and receives /lowstate, as on the real robot. The simulators also publish the lidar scan, odometry and head camera.
One safety layer
All input sources send requests to the mode manager. It uses a control lease, a watchdog, an emergency-stop gate and speed zones.
One building
One Python layout file defines the hospital. It generates the Isaac scene and the MuJoCo walls in the same world frame, so a map from one simulator is correct in the other.
World
The hospital is the NVIDIA Isaac Sim hospital building. A generated surgical wing connects to its south-east door, with the operating theatre and props of NVIDIA Isaac for Healthcare and Lightwheel SimReady.
A generator builds the scene from the layout file. A build check stops the build if furniture blocks a door, if two props overlap or if a prop is outside its room. The corridors are 2 m and 4 m wide, and the doors have 2 m of clear width. A reduced copy of the assets runs on an 8 GB graphics card.
Simulation for training and test
Two simulators replace the robot and use the same low-level interface. MuJoCo provides fast physics: the ROS 2 simulator node steps it at 500 Hz, and MuJoCo MJX trains the controller. Isaac Sim provides realistic rendering, a GPU lidar and a head camera for tests of navigation and perception.
Controller training
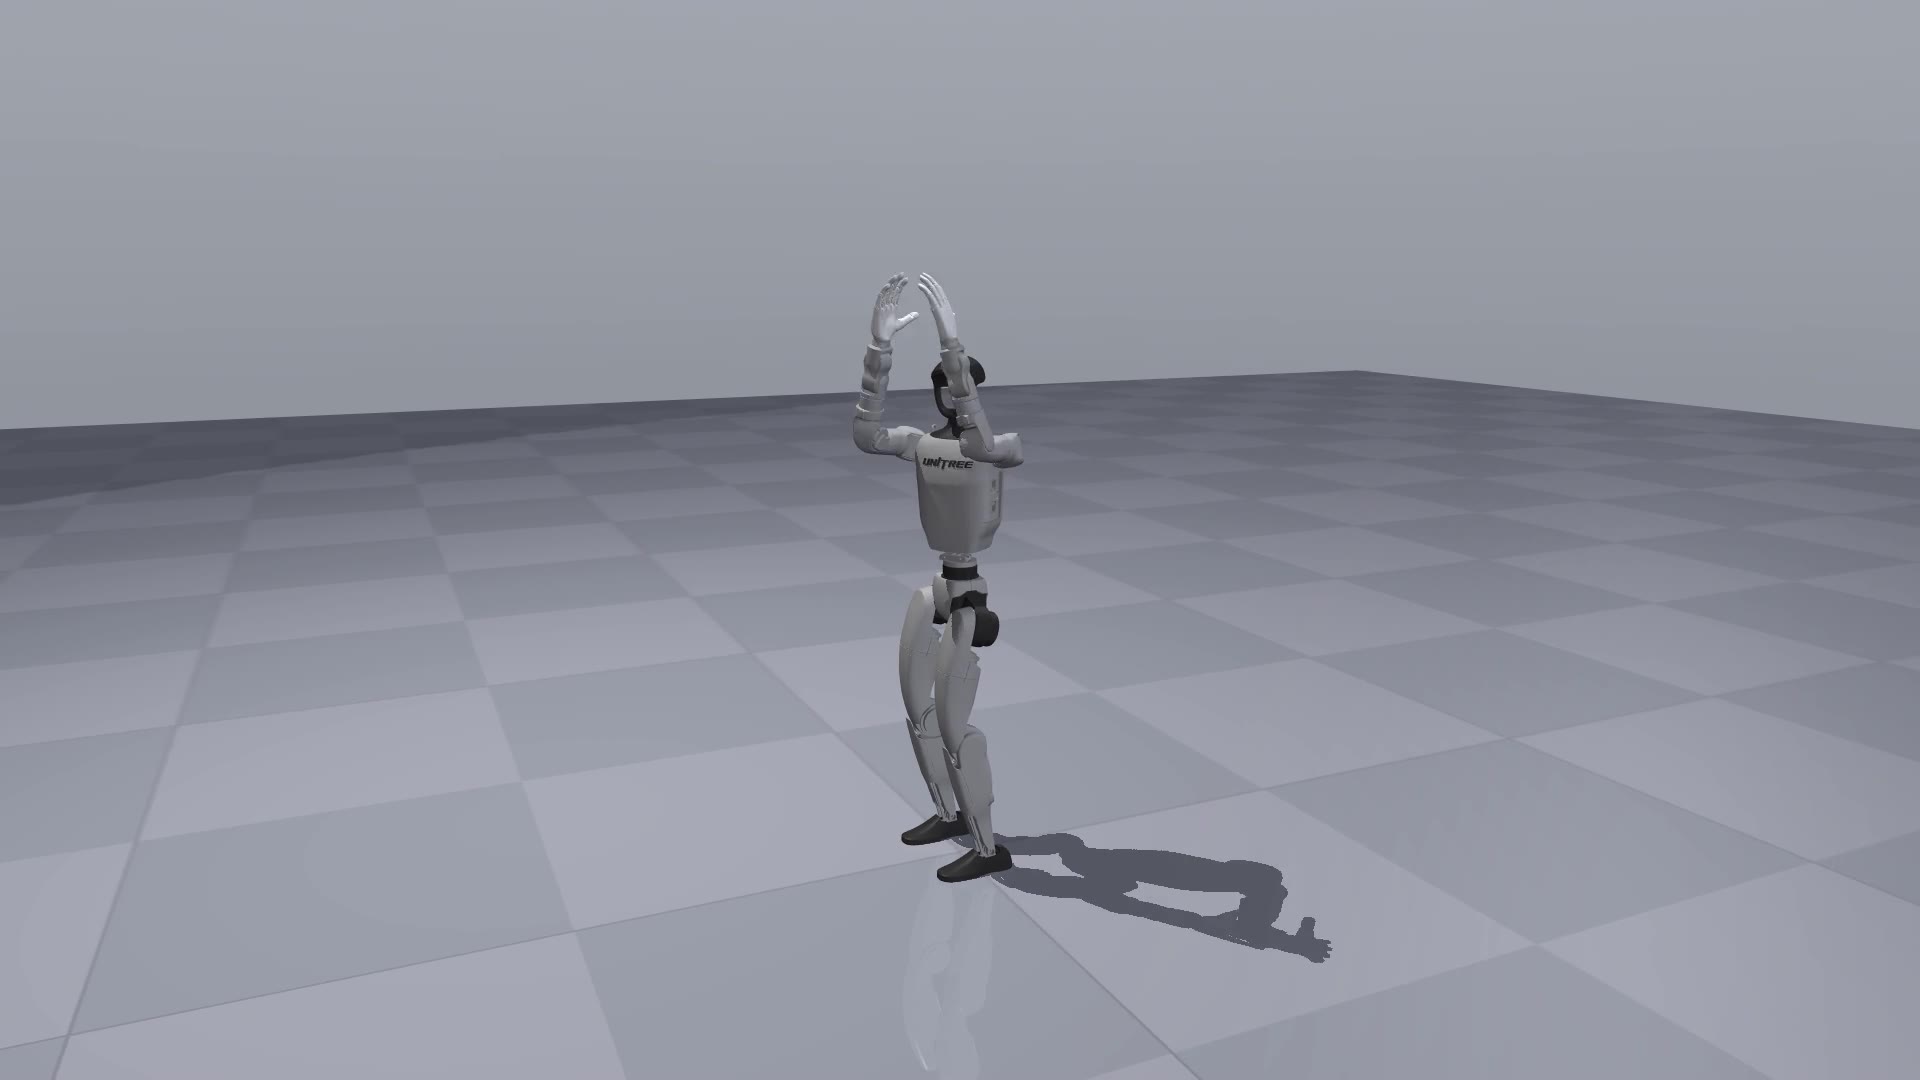
PPO trains the whole-body controller in MuJoCo MJX, with 2048 robots in parallel on one RTX 3070. The curriculum has three stages: stand (A), walk with arm targets (B) and follow full-body motions (C). A teacher policy with privileged data trains a student policy that uses only the sensors of the real robot. The controller loads the student as an ONNX file.
Stage A1 is complete. Survival increased from 0.05 to 0.97 in 39 million steps, in approximately one hour. Before training, the policy falls after 1.0 s; after training, it stands for the full 11 s test with a maximum tilt of 2.7 degrees.
Teleoperation and safety
All input sources send requests to the mode manager, which makes the decision. A control lease sets which source has control. A watchdog sets HOLD if the interface signal stops. A hardware emergency stop has priority over all inputs, and speed zones on the map set the maximum speed. Webcam teleoperation, with MediaPipe and a fork of xr_teleoperate, controls the arms and hands without a VR headset.
Autonomy
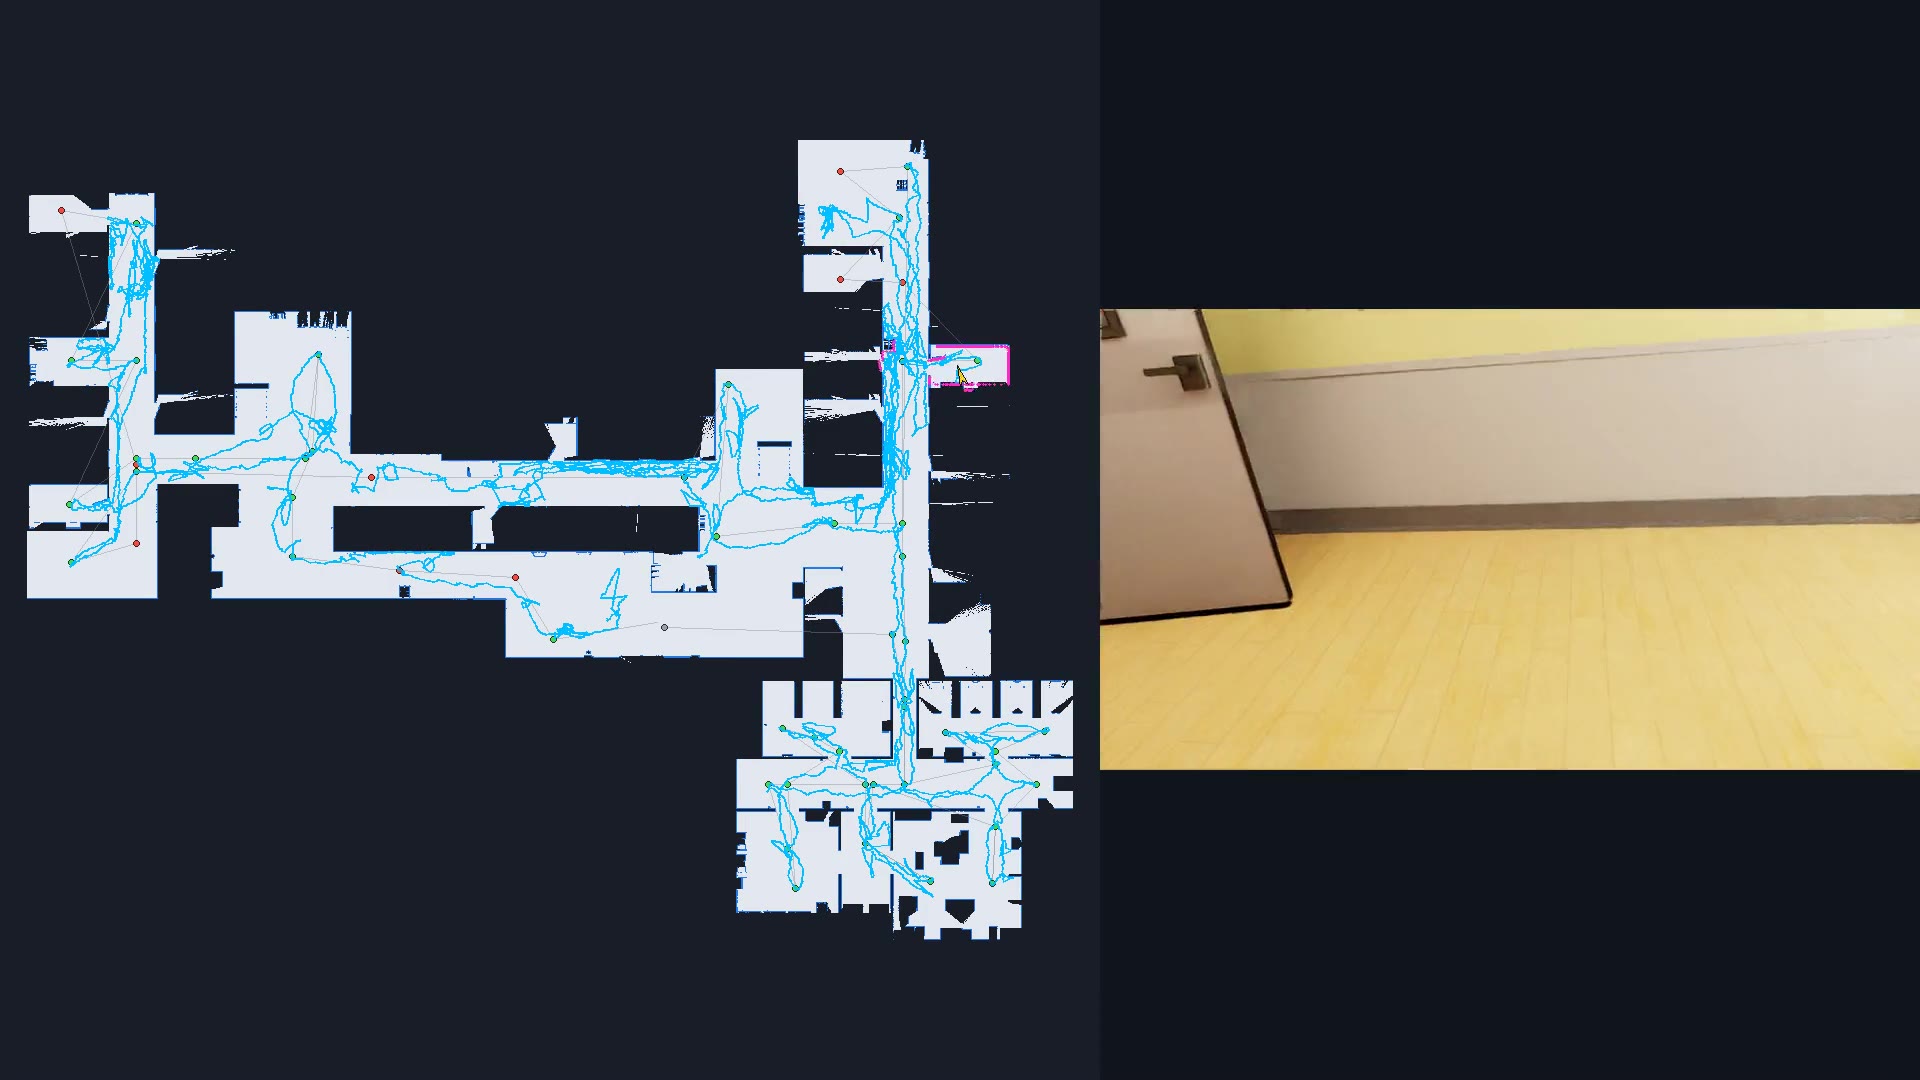
Navigation uses standard ROS 2 packages: slam_toolbox builds the map, AMCL localises the robot, and Nav2 with the MPPI controller plans the path. In the test, the robot followed a route of 60 points through the hospital and the surgical wing.
Mode manager · seven modes
Status and next steps
Components
- hospital-sim
- Master repository: interface contract, environment script, component list
- …-env
- Isaac Sim hospital and surgical wing, layout generator
- …-description
- Robot model: URDF, MJCF, meshes, specification
- …-mujoco-sim
- MuJoCo hospital from the same layout
- …-isaac-sim
- Physics layer, lidar, cameras, DDS and ROS 2 bridge
- …-whole-body-rl
- Controller training in MuJoCo MJX, ONNX export
- …-ros2
- Controller, mode manager, teleoperation, navigation, tasks
- …-webcam-teleop
- Webcam teleoperation of the arms and hands
Stills
Select a still to enlarge it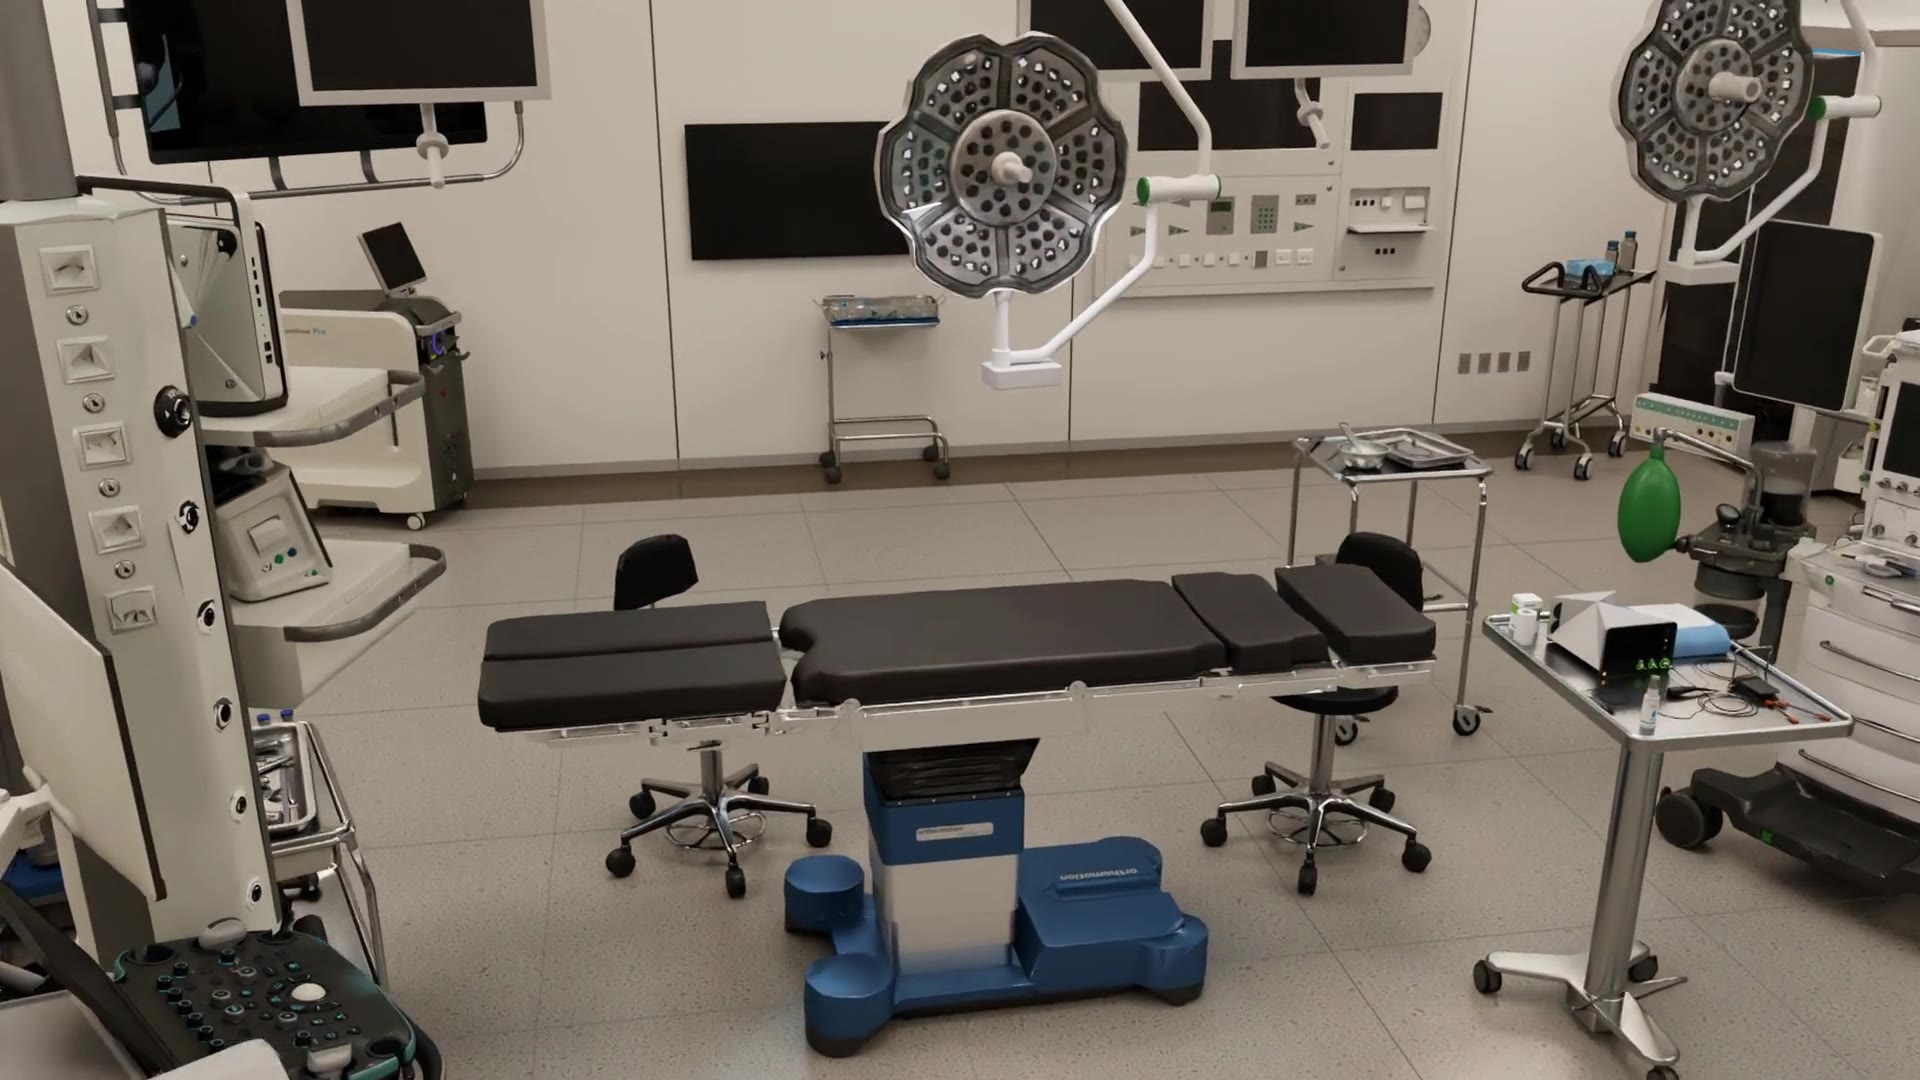
Disclaimer. WardZero is research software in development. All tests used simulation only. WardZero is not a medical device. It is not for patient care, for a clinical procedure, or for the control of a real robot near people without a separate safety analysis, tests and approvals.
Assets. Hospital building: NVIDIA Isaac Sim (NVIDIA Limited Use Content). Operating theatre: NVIDIA Isaac for Healthcare (Apache 2.0). Surgical props: Lightwheel SimReady assets © Lightwheel AI, CC BY-NC 4.0. Robot: Unitree G1 descriptions from unitree_ros and BrainCo Revo2 hand descriptions. Based on hospital-sim by Bkrakshith.